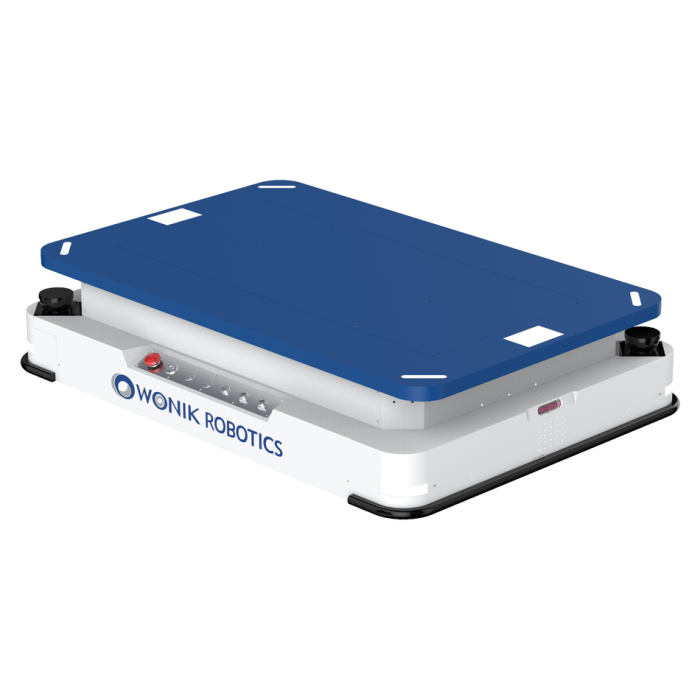
Wonik Robotics WR1000LF
In stock
- HANDELSMERK:
- Wonik Robotics
- MODEL:
- WR1000LF
- DEEL #:
- WR1000LF
- Warranty:
- 12 MAANDE
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-WR1000LF
Wonik Robotics WR1000LF
Overview
The Wonik Robotics WR1000LF is an autonomous mobile robot (AMR) built around a pallet lift loading method and a differential drive system. According to the manufacturer's published specification, the platform carries payloads of up to 1,000 kg, reaches a maximum speed of 1 m/sec and operates for about 12 hours per charge.
With the lift module included, the chassis measures 956 x 1,350 x 318 mm, a low profile that reflects the geometry required for under-pallet entry.
Design and Construction
The listed dimensions of 956 mm width, 1,350 mm length and 318 mm height (with the lift module) describe a flat, rectangular platform. The loading method is a pallet lift with a 100 mm stroke, meaning the lifting surface travels 100 mm between its lowered and raised positions. This stroke is used to pick a pallet clear of its resting position and hold it off the floor during transport, after which the lift lowers the pallet at the drop-off point.
Propulsion comes from a differential drive arrangement. The specification lists two urethane driving wheels of 8-inch (20 cm) size, supported by additional sub wheels that stabilize the platform; the source does not state the sub wheel dimensions.
Specifications
The table below summarizes the manufacturer-published specifications for the WR1000LF.
| Item | Specification |
|---|---|
| Configuration | Pallet Lift |
| Navigation Type | SLAM |
| Dimensions (W x L x H) | 956 x 1,350 x 318 mm (with lift module) |
| Payload | 1,000 kg |
| Driving System | Differential Drive |
| Driving Wheels | Urethane, 8-inch (20 cm) x 2 |
| Loading Method | Pallet Lift (100 mm stroke) |
| Stop Accuracy | +/- 20 mm |
| Docking Accuracy (with QR code) | +/- 10 mm |
| Maximum Speed | 1 m/sec |
| Average Speed | About 0.7 m/sec |
| Battery | Li-ion, DC 50 V / 50 Ah |
| Operating Time | About 12 hours |
| Charging Time | About 2 to 2.5 hours |
| Charging Method | Auto / Manual |
| Battery Charging Method | Automatic sliding-type charging |
| Communication | Wi-Fi 2.4 GHz and 5 GHz; LTE/5G support (optional) |
Operational Considerations
The specification distinguishes between two positioning figures, and the difference matters in practice. Stop accuracy of +/- 20 mm describes how closely the robot halts at an ordinary destination during normal travel. Docking accuracy of +/- 10 mm applies when the robot aligns to a QR code reference, the tighter tolerance used for structured interactions such as approaching defined docking positions. Planning should treat these as separate values rather than a single accuracy rating.
Speed is listed as 1 m/sec maximum with an average of about 0.7 m/sec. The average figure is the more realistic basis for estimating cycle times, since acceleration, deceleration, turns and alignment phases keep a loaded vehicle below its peak speed for much of a route. Both figures are approximate operating characteristics rather than guarantees.
Power comes from a lithium-ion battery rated DC 50 V / 50 Ah, supporting about 12 hours of operation, with a recharge taking roughly 2 to 2.5 hours. Actual runtime varies with load, duty cycle and route profile.
For connectivity, the robot supports Wi-Fi on both 2.4 GHz and 5 GHz bands. LTE/5G support is listed as optional, so cellular communication should be treated as an add-on choice rather than a standard inclusion.
Applications
As a 1,000 kg pallet lift AMR, the WR1000LF is oriented toward internal pallet movement in industrial environments. Typical duties for this class of vehicle include transferring palletized goods between receiving, storage, production and dispatch areas, feeding palletized materials to work cells and handling repetitive point-to-point pallet runs that would otherwise occupy manually driven equipment.
The SLAM navigation approach suits facilities where routes may need to change over time, since mapping is software-defined rather than fixed in the floor. The roughly 12-hour operating time combined with a 2 to 2.5 hour recharge and automatic charging supports scheduling across extended shifts, with charging windows planned around workload.
Frequently Asked Questions
How much weight can the WR1000LF carry?
The manufacturer rates the payload at 1,000 kg.
How accurate is the positioning?
Two figures are published: stop accuracy of +/- 20 mm for general halting at destinations, and docking accuracy of +/- 10 mm when aligning with a QR code reference. The tighter docking figure applies specifically to QR-assisted alignment, not to every stop.
How long does the robot run and how is it charged?
Operating time is about 12 hours, with charging taking roughly 2 to 2.5 hours.
What navigation technology does it use?
The WR1000LF navigates with SLAM, building a map of the facility and localizing within it.
What communication options are available?
The robot supports Wi-Fi on 2.4 GHz and 5 GHz bands as standard. LTE/5G support is available as an option, so facilities requiring cellular connectivity should specify it when configuring the vehicle.
How does the differential drive affect maneuvering?
This drive style is well suited to confined aisle layouts where a tight turning behavior is needed.
Summary
The Wonik Robotics WR1000LF is a pallet lift autonomous mobile robot combining a 1,000 kg payload, SLAM navigation and differential drive in a 956 x 1,350 x 318 mm platform. Published figures include 1 m/sec maximum speed, about 0.7 m/sec average speed, +/- 20 mm stop accuracy, +/- 10 mm QR-assisted docking accuracy, a DC 50 V / 50 Ah lithium-ion battery with about 12 hours of operation and automatic sliding-type charging in roughly 2 to 2.5 hours. Wi-Fi is standard and LTE/5G is optional, making the WR1000LF a candidate for repetitive heavy pallet transport in mapped industrial facilities.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.