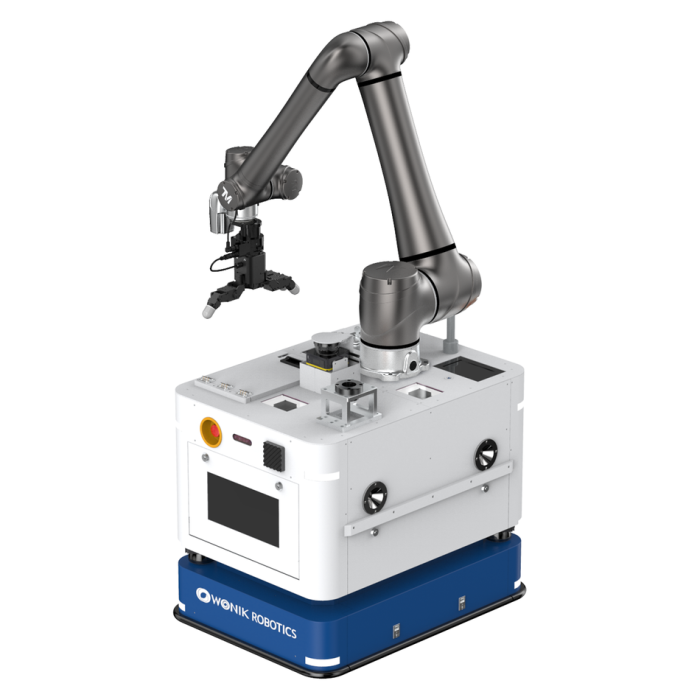
Wonik Robotics WR-AMMR12-3F
In stock
- HANDELSMERK:
- Wonik Robotics
- MODEL:
- WR-AMMR12-3F
- DEEL #:
- WR-AMMR12-3F
- Warranty:
- 12 MAANDE
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-WR-AMMR12-3F
Wonik Robotics WR-AMMR12-3F
Overview
The Wonik Robotics WR-AMMR12-3F is an autonomous mobile manipulation robot (AMMR) that combines a mecanum-wheel mobile platform (WR-AMR) with a collaborative robot arm. According to the manufacturer, the AMMR family integrates an AMR, a collaborative robot and an end effector, with intended task areas that include material transport, assembly, palletizing and machine tending. These are family-level contexts rather than guaranteed turnkey applications of this exact configuration, so suitability for a specific task should be evaluated against the actual process requirements.
In this configuration, the mobile base carries a Techman TM12 manipulator rated at a 12 kg payload with a 1,300 mm reach. The platform uses SLAM-based navigation and an automatic battery charging and swap arrangement, with a quoted operating time of 5 hours. The end effector is listed as optional, as discussed below.
Mobile Platform and Mecanum Drive
The mobile platform measures 700 x 950 x 810 mm (W x L x H). The manufacturer states these dimensions for the mobile platform only, not for the complete assembled robot with the manipulator mounted, so clearance and layout planning should be treated as a consideration to confirm during project engineering rather than derived from the platform figure alone.
The drive system uses urethane mecanum wheels, specified as two 6-inch (15 cm) driving wheels plus four sub wheels. Mecanum wheels allow omnidirectional movement, which the manufacturer associates with directional changes and positioning in confined workspaces. Maximum speed is 1 m/sec, with an average speed of about 0.5 m/sec; speeds actually used in a deployment are a planning consideration influenced by floor condition, traffic and safety zoning.
Manipulator and Payload: Two Different Figures
The specification contains two separate load figures that should not be confused.
- Manipulator payload: 12 kg. The Techman TM12 arm is rated at a 12 kg payload with a 1,300 mm reach. This is the maximum mass the arm itself is specified to handle.
- Platform payload: 100 kg (with manipulator). This figure describes the load capacity of the mobile platform in its manipulator-equipped configuration; it is not the arm's lifting capacity and should not be read as 100 kg of additional capacity on top of other loads.
In practical terms, the arm handles items up to its 12 kg rating, while the 100 kg figure relates to what the base is specified to carry with the manipulator fitted. Usable transport capacity remaining for fixtures or workpieces in a specific build-out is an engineering consideration to confirm with the manufacturer.
End Effector Configuration
The configuration list describes the end effector as optional, while the specification table names the Allegro Hand V5 with a pressure sensor under the end effector item. The Allegro Hand V5 is therefore the end effector named in the specification, but the optional designation means an end effector should not be assumed to be supplied by default. The end effector arrangement is a configuration matter to confirm at the time of specification and ordering.
Navigation, Positioning, Battery and Communication
Navigation is SLAM-based, so the robot localizes and maps using onboard sensing rather than fixed guidance infrastructure. Stop accuracy is quoted at ±10 mm and docking accuracy at ±1 mm; processes needing fine, repeatable positioning at a workstation would, as a planning consideration, rely on docking to reach the tighter tolerance.
The battery is lithium-ion, specified at DC 50 V / 50 Ah, with a charging time of about 1 to 1.5 hours and both automatic and manual charging. The battery charging method is an automatic sliding-type charging and swap system. The quoted operating time is 5 hours; this is the manufacturer's stated figure, not a guaranteed runtime under every load condition, since duty cycle, carried load and manipulator activity all influence consumption.
Connectivity is Wi-Fi at 2.4 GHz and 5 GHz with an external patch antenna, with optional LTE/5G support. Wireless coverage across the operating area is a standard site-preparation consideration.
Key Specifications
| Item | Specification |
|---|---|
| Configuration | WR-AMR mobile platform, mecanum wheels, Techman TM robot arm, end effector (optional) |
| Manipulator | Techman TM12, payload 12 kg, reach 1,300 mm |
| Platform payload | 100 kg (with manipulator) |
| Dimensions (W x L x H) | 700 x 950 x 810 mm (mobile platform only) |
| Navigation | SLAM |
| Drive system | Mecanum wheel; urethane, driving 6 in (15 cm) x 2, sub x 4 |
| End effector (named in specification) | Allegro Hand V5 (with pressure sensor); optional in configuration |
| Maximum speed | 1 m/sec |
| Average speed | About 0.5 m/sec |
| Stop accuracy | ±10 mm |
| Docking accuracy | ±1 mm |
| Battery | Li-ion, DC 50 V / 50 Ah |
| Charging time | About 1 to 1.5 hr |
| Charging method | Auto / manual; automatic sliding-type charging and swap system |
| Operating time | 5 h (stated figure) |
| Network | Wi-Fi 2.4 GHz / 5 GHz with external patch antenna; optional LTE/5G |
Frequently Asked Questions
What is the payload of the Wonik Robotics WR-AMMR12-3F?
There are two distinct figures. The Techman TM12 manipulator is rated at 12 kg, the maximum the arm handles. Separately, the mobile platform is specified at 100 kg payload with the manipulator fitted — a platform capacity in that configuration, not the arm's lifting capacity and not 100 kg of extra capacity.
Do the stated dimensions describe the whole robot?
No. The 700 x 950 x 810 mm dimensions apply to the mobile platform only. A complete assembled robot with the manipulator mounted will have different overall dimensions, so clearance planning should not rely on the platform figure alone.
Is an end effector included by default?
The configuration lists the end effector as optional. The specification names the Allegro Hand V5 with a pressure sensor, but this does not guarantee it is supplied by default; confirm the end effector arrangement when specifying the system.
How long does the robot run on a charge?
The manufacturer quotes 5 hours of operating time and about 1 to 1.5 hours of charging for the Li-ion DC 50 V / 50 Ah battery. The 5-hour figure is a stated value, not guaranteed under every load condition.
How accurate is its positioning?
Stop accuracy is ±10 mm and docking accuracy is ±1 mm. For fine, repeatable positioning at a station, docking is the mechanism associated with the tighter tolerance.
What tasks is it intended for?
The AMMR family is positioned for material transport, assembly, palletizing and machine tending, with mecanum mobility supporting positioning in confined workspaces. These are family-level intended tasks, not guaranteed turnkey applications of this exact configuration; fit should be validated against the arm payload, reach, accuracy figures and the chosen end effector.
Summary
The Wonik Robotics WR-AMMR12-3F pairs a SLAM-navigating, mecanum-wheel mobile platform with a Techman TM12 collaborative arm rated at 12 kg payload and 1,300 mm reach, with the platform specified at 100 kg payload in the manipulator-equipped configuration. The platform measures 700 x 950 x 810 mm (platform only), reaches 1 m/sec, stops within ±10 mm, docks within ±1 mm, and runs on a 50 V / 50 Ah Li-ion battery with roughly 1 to 1.5 hour charging, an automatic sliding-type charging and swap system, and a stated 5-hour operating time. The end effector is optional, with the Allegro Hand V5 (with pressure sensor) named in the specification. Within an AMMR family intended for material transport, assembly, palletizing and machine tending, this configuration is a candidate for mobile manipulation work provided the application is validated against its stated payloads, reach, accuracy and runtime figures.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.